PseudoMotor
Classes
PseudoMotor
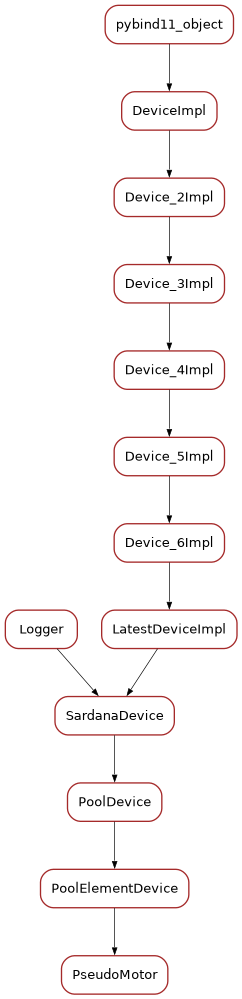
- class PseudoMotor(dclass, name)[source]
Bases:
PoolElementDevice- ignore_memorized_attrs_during_initialization = ('Position',)
- init(name)[source]
initialize the device once in the object lifetime. Override when necessary but always call the method from your super class
- Parameters:
name – device name
- property pseudo_motor
- delete_device()[source]
Clean the device. Called during shutdown and every time the tango
Initcommand is executed. Override when necessary but always call the method from your super class
- init_device()[source]
Initialize the device. Called during startup after
init()and every time the tangoInitcommand is executed. Override when necessary but always call the method from your super class
- get_dynamic_attributes()[source]
Override of
PoolDevice.get_dynamic_attributes. Returns the standard dynamic and fully dynamic attributes for this device. The return is a tuple of two dictionaries:standard attributes: caseless dictionary with key being the attribute name and value is a tuple of attribute name(str), tango information, attribute information
dynamic attributes: caseless dictionary with key being the attribute name and value is a tuple of attribute name(str), tango information, attribute information
- tango information
seq<
CmdArgType,AttrDataFormat,AttrWriteType>- attribute information
attribute information as returned by the sardana controller
- Returns:
the standard dynamic and fully dynamic attributes
- CalcPseudo(physical_positions)[source]
Returns the pseudo motor position for the given physical positions
- CalcPhysical(pseudo_position)[source]
Returns the physical motor positions for the given pseudo motor position assuming the current pseudo motor write positions for all the other sibling pseudo motors
- CalcAllPhysical(pseudo_positions)[source]
Returns the physical motor positions for the given pseudo motor position(s)
- CalcAllPseudo(physical_positions)[source]
Returns the pseudo motor position(s) for the given physical positions
- is_Position_allowed(req_type)
Generic is_allowed
PseudoMotorClass
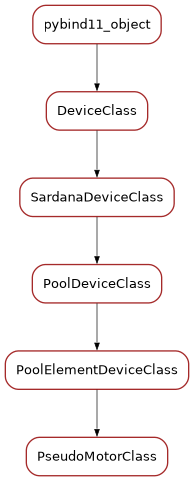
- class PseudoMotorClass(name)[source]
Bases:
PoolElementDeviceClass- class_property_list = {}
Sardana device class properties definition
- device_property_list = {'Axis': [CmdArgType.DevLong64, 'Axis in the controller', [0]], 'Ctrl_id': [CmdArgType.DevString, 'Controller ID', [0]], 'DriftCorrection': [CmdArgType.DevBoolean, 'Locally apply drift correction on pseudo motors. Default is the current global drift correction in the Pool Device', None], 'Force_HW_Read': [CmdArgType.DevBoolean, 'Force a hardware read of value even when in operation (motion/acquisition', False], 'Id': [CmdArgType.DevLong64, 'Internal ID', 0], 'Instrument_id': [CmdArgType.DevString, 'Instrument ID', [0]]}
Sardana device properties definition
- cmd_list = {'Abort': [[CmdArgType.DevVoid, ''], [CmdArgType.DevVoid, '']], 'CalcAllPhysical': [[CmdArgType.DevVarDoubleArray, 'pseudo positions'], [CmdArgType.DevVarDoubleArray, 'physical positions']], 'CalcAllPseudo': [[CmdArgType.DevVarDoubleArray, 'physical positions'], [CmdArgType.DevVarDoubleArray, 'pseudo positions']], 'CalcPhysical': [[CmdArgType.DevDouble, 'pseudo position'], [CmdArgType.DevVarDoubleArray, 'physical positions']], 'CalcPseudo': [[CmdArgType.DevVarDoubleArray, 'physical positions'], [CmdArgType.DevDouble, 'pseudo position']], 'MoveRelative': [[CmdArgType.DevDouble, 'amount to move'], [CmdArgType.DevVoid, '']], 'Release': [[CmdArgType.DevVoid, ''], [CmdArgType.DevVoid, '']], 'Restore': [[CmdArgType.DevVoid, ''], [CmdArgType.DevVoid, '']], 'Stop': [[CmdArgType.DevVoid, ''], [CmdArgType.DevVoid, '']]}
Sardana device command definition
- standard_attr_list = {'Position': [[CmdArgType.DevDouble, AttrDataFormat.SCALAR, AttrWriteType.READ_WRITE], {'abs_change': '1.0', 'label': 'Position'}]}